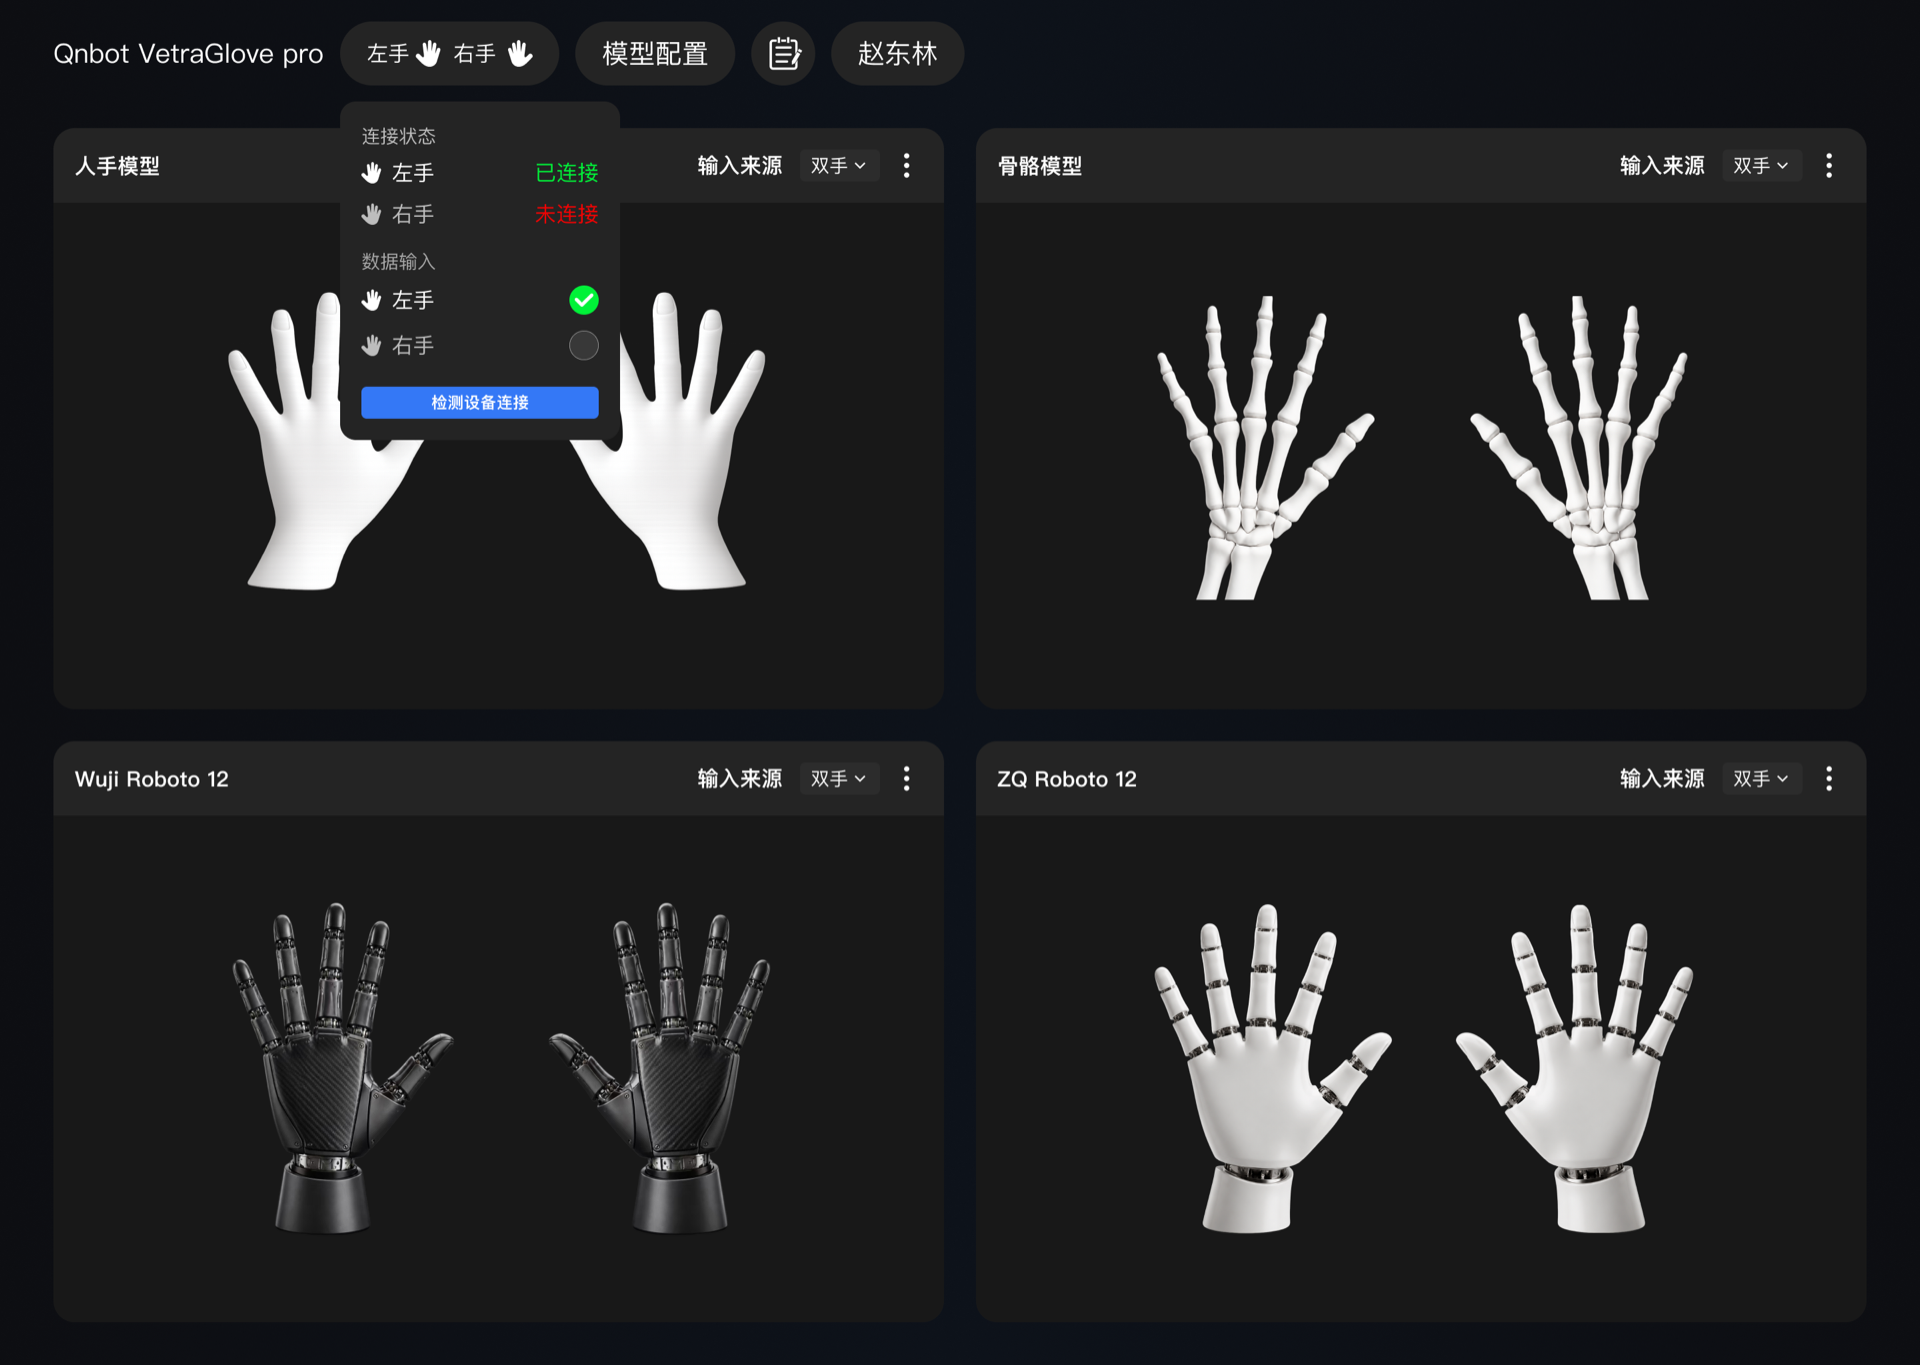
Qnbot Studio
Connect and manage gloves, preview both hands, configure models, retarget motion, and control robotic hands in real time.
View desktop app docsLet MCP-compatible developer tools search and read Qnbot documentation directly.
Install and manage local or authorized online algorithm packages, then verify the development environment.
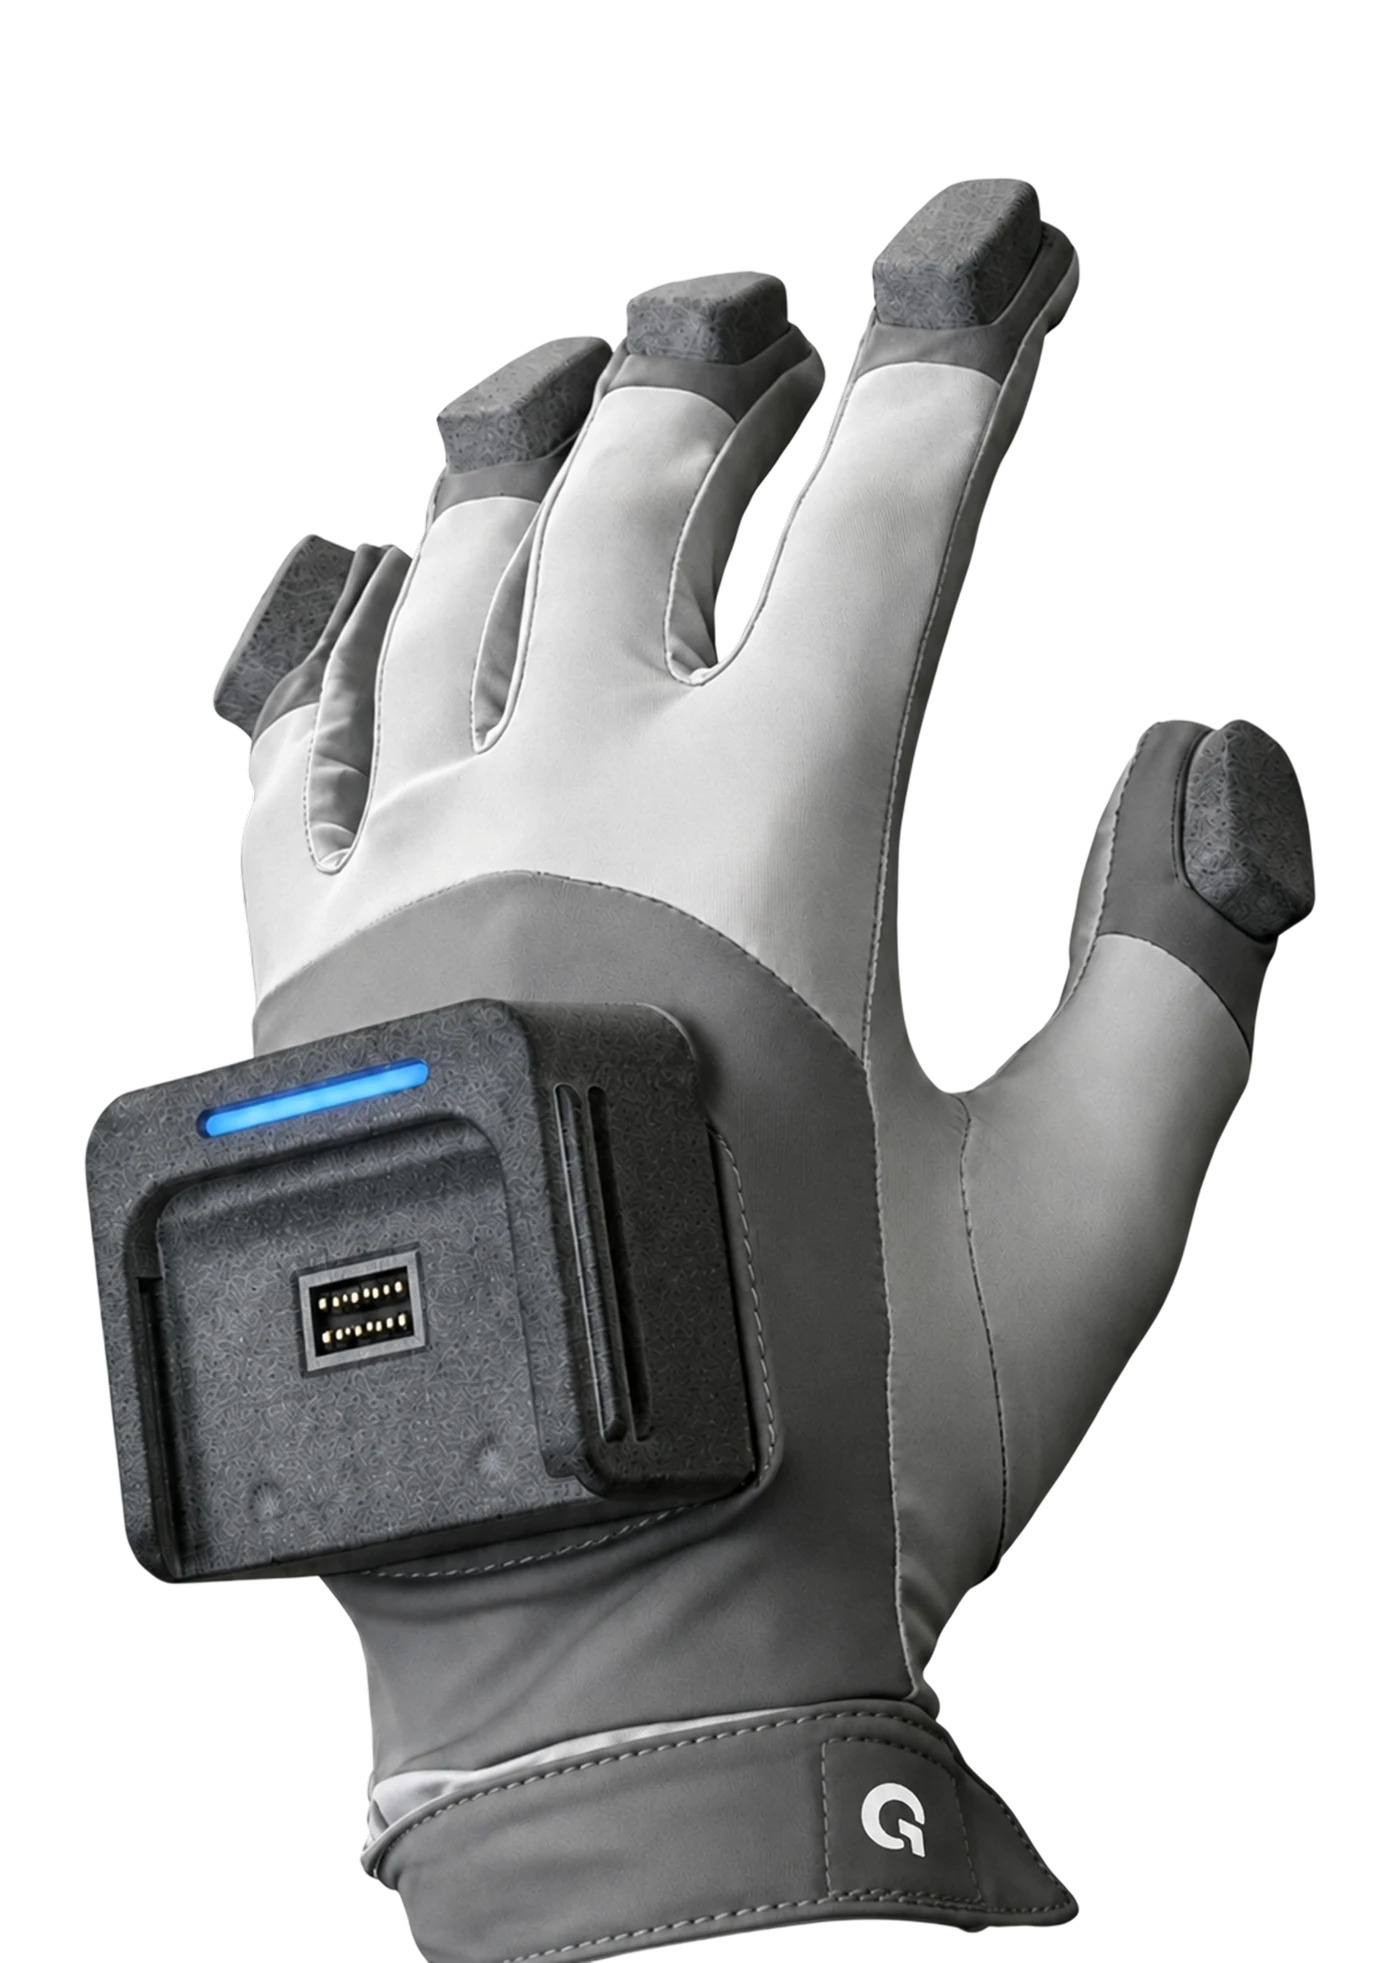
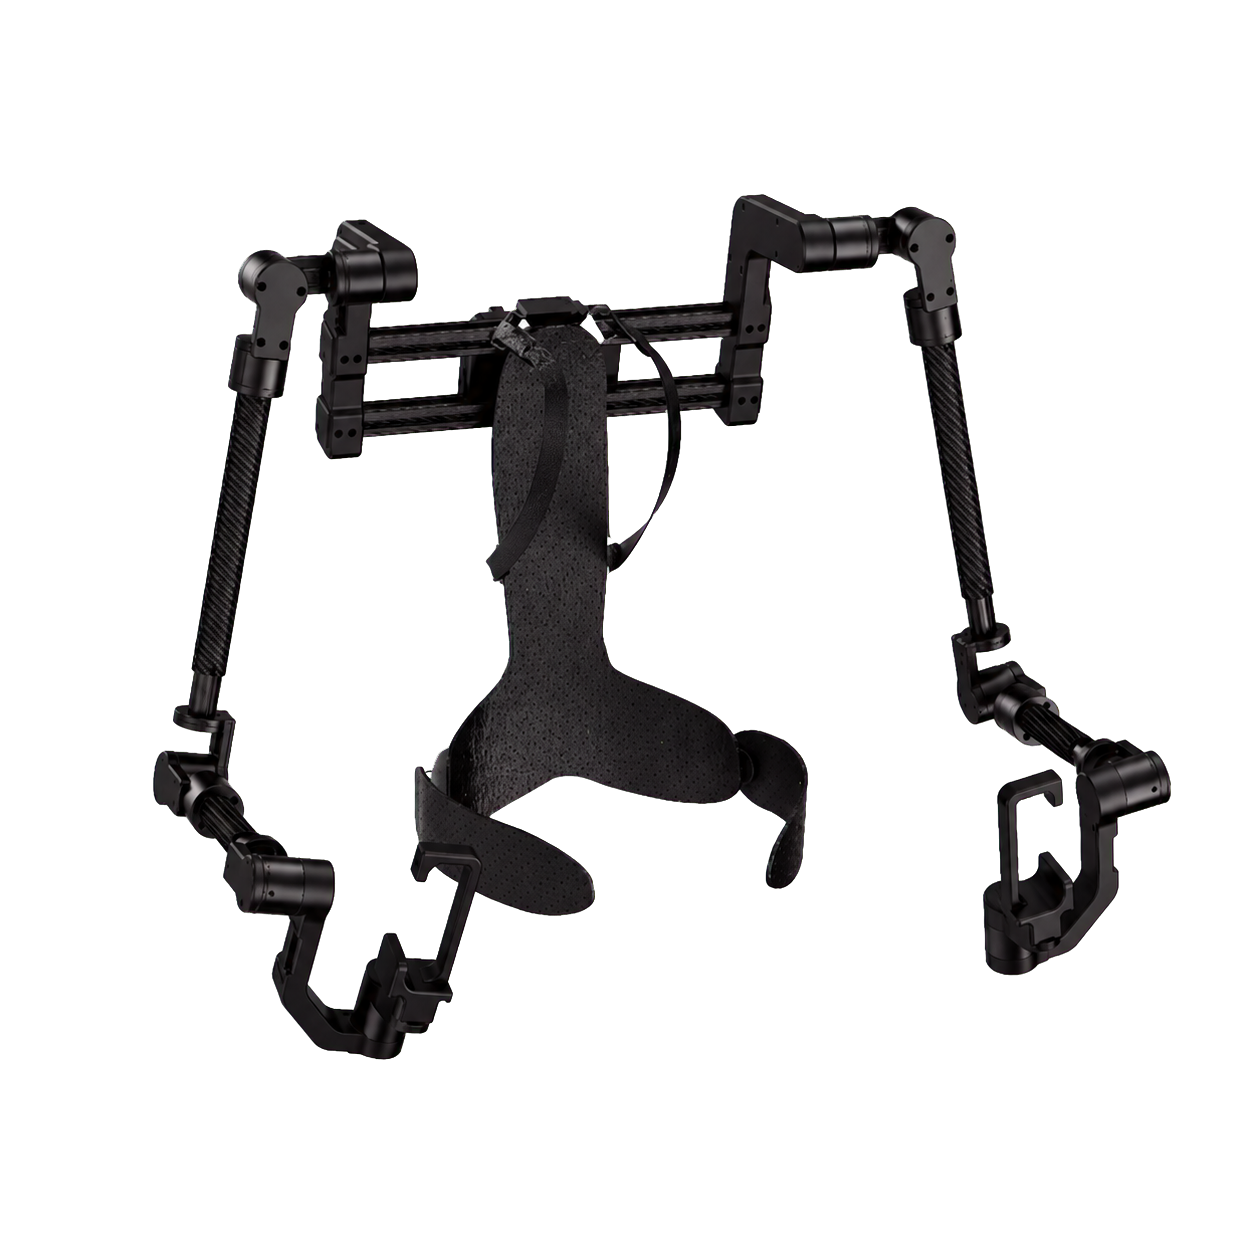
Natural input for teleoperation and motion capture in a lightweight frame.
View exoskeleton docsConnect and manage gloves, preview both hands, configure models, retarget motion, and control robotic hands in real time.
View desktop app docsUse Python and C++ to read glove data, run motion retargeting, and control haptic feedback.
View SDK docsConnect, calibrate, preview data, and debug haptic feedback for the glove.
Connect the exoskeleton, configure joints, monitor runtime status, and run diagnostics.
Read glove data, consume retargeting output, and control haptic feedback.
Read exoskeleton status, control joints, and run diagnostics.
Output reference for robotic-hand joint commands and the Dynamic OpenXR 25-joint skeleton pose.
Install and manage local or authorized online algorithm packages, including access setup, inspection, and removal.
Search and read Qnbot documentation from coding agents.